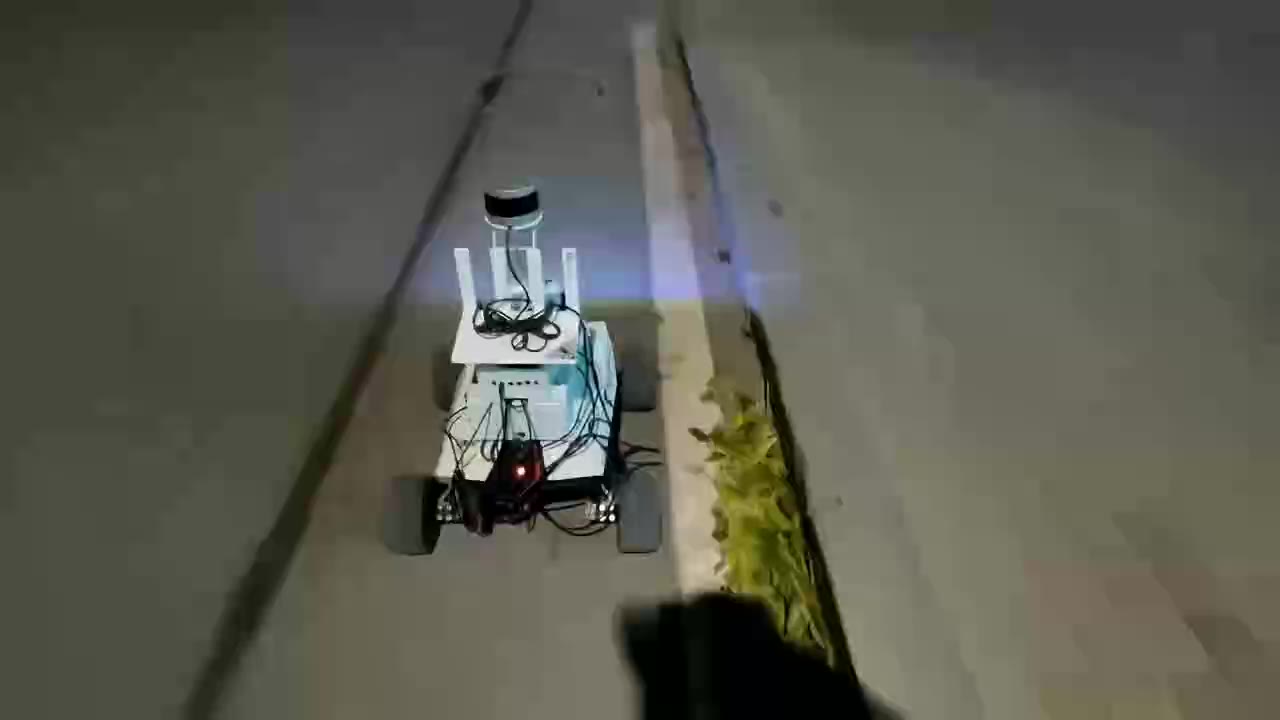
 SCOUT MINI / FIELD EXPERIMENT
MOBILE ROBOTICS / 01
Scout Mini Curb-following System
基于激光雷达的路沿检测与移动机器人贴边控制。从点云感知、多帧跟踪,到车身几何约束下的目标生成与运动控制,探索移动机器人沿真实道路边缘行驶的完整流程。
Explore the projectRESEARCH PORTFOLIO
Ph.D. Student in
Transportation Engineering
Harbin Institute of
Technology
RESEARCH INTERESTS
Exploring 3D vision and 4D scene reconstruction for autonomous driving, with a focus on dynamic scene representation and inverse rendering.
SCOUT MINI / FIELD EXPERIMENTMOBILE ROBOTICS / 01
基于激光雷达的路沿检测与移动机器人贴边控制。从点云感知、多帧跟踪,到车身几何约束下的目标生成与运动控制,探索移动机器人沿真实道路边缘行驶的完整流程。
Explore the project点云感知 · 连续跟踪 · 机器人运动控制